Digital Communications: A Discrete-Time Approach
by Michael Rice
Symbol Timing Synchronization for Binary Baseband PAM
Introduction
The previous Binary Baseband PAM Simulink Exercise assumed the phase of the bit clock was known. That is, you knew where the symbols began and ended. Unfortunately, this is not the case in practice and the bit (or symbol) timing must be extracted from the received signal samples. This is accomplished using a bit (or symbol) timing synchronizer.In this exercise, you will design a bit timing synchronizer for binary baseband PAM based on the PLL. There are three sample rates in play in this design, so you must be careful in assigning sample times to the simulink blocks. The detector, with its accompanying bit timing synchronizer, will be used to process the modulated sampled in the file bbtrdata.mat.
Textbook References
Baseband PAM: Section 5.2, discrete-time realizations: Section 5.2.2, partial response pulse shapes: Section A.2, general discussion of timing synchronization: Section 8.1, discrete-time techniques for symbol timing synchronization for binary PAM: Section 8.4.Specifications
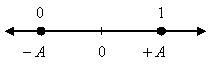 |
|
Preliminary Design
Design the Detector
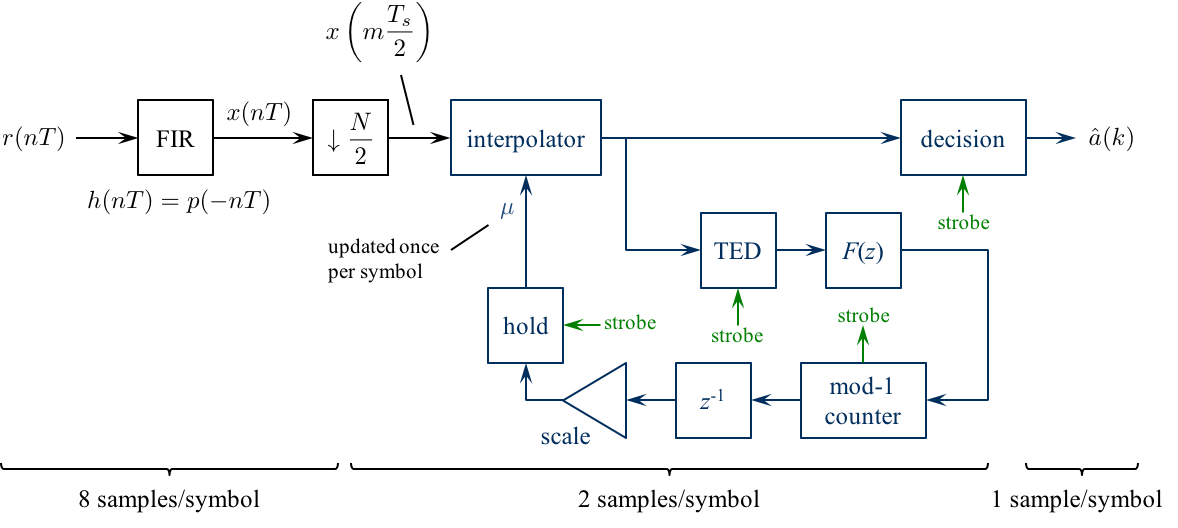
Design the detector, shown below, using blocks from the Simulink, DSP System, and Communications System Toolboxes.
Design the loop filter to create a second order loop to the following specifications: closed-loop equivalent noise bandwidth = 0.01 (normalized to the bit rate), damping factor = 0.7071.
Design Notes
- Because the early-late TED operates at 2 samples/symbol, the matched filter output output (at 8 samples/symbol) is downsampled by 4.
- Use a Farrow interpolator. You can use either the piecewise-parabolic version (Figure 8.4.17) or the cubic version (Figure 8.4.18).
- For interpolation control, use the decrementing modulo-1 counter described in Section 8.4.3. Use the underflow condition in the decrementing mod-1 counter as the strobe. The strobe is used as an enable signal for the TED, decision, and mu update.
- You need to create an "enabled" version of the early-late TED. When the strobe is asserted, the TED output is given by equation (8.34). When the strobe is not asserted, the TED output is zero.
-
For the fractional interval (mu) update, use an "enabled hold" block.
The "enabled hold" block outputs the previous value when the strobe is not asserted,
or passes the input to the output when the strobe is asserted.
This block is needed because the fractional interval is updated by the mod-1
counter only once per symbol, but the interpolator operates at 2 samples/symbol.
The hold operation ensures that the interpolator is using the proper value for
the fractional interval.
Simulink provides a skeletal enabled subsystem:
Simulink -> Ports & Subsystems -> Enabled Subsystem
The default enabled subsystem is shown below
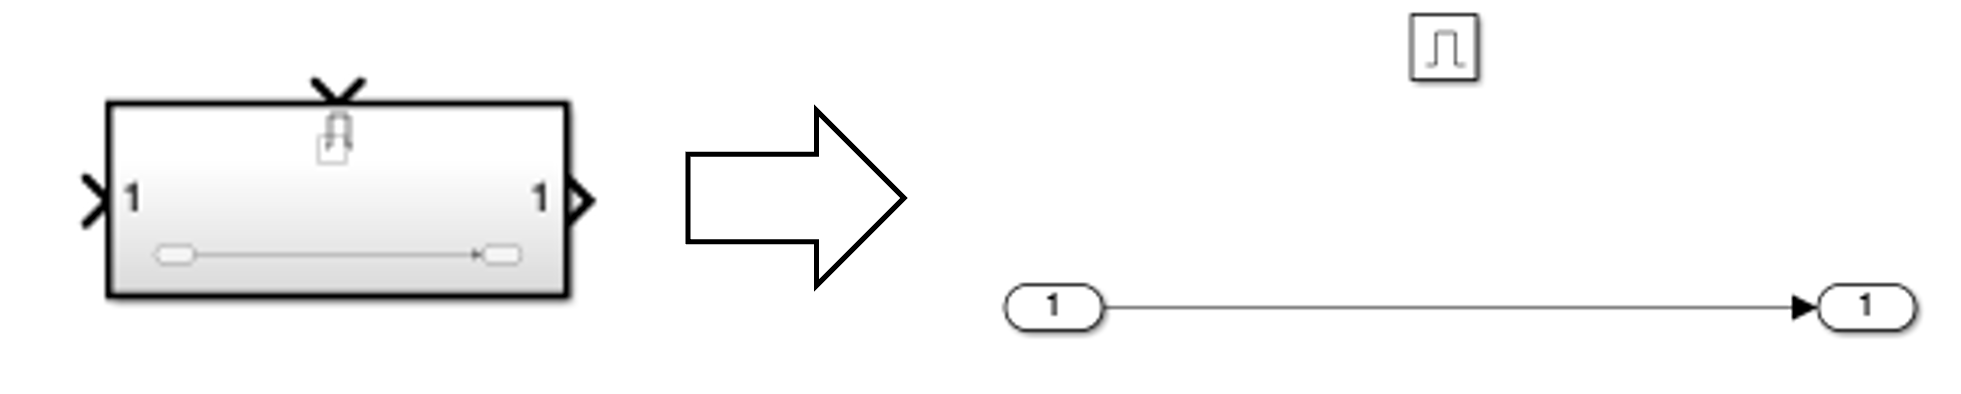
The subsystem consists of a simple wire with the enable icon above it. This means the wire is only active when the enable signal is asserted. When the enable signal is not asserted, nothing happens and the output holds its value. -
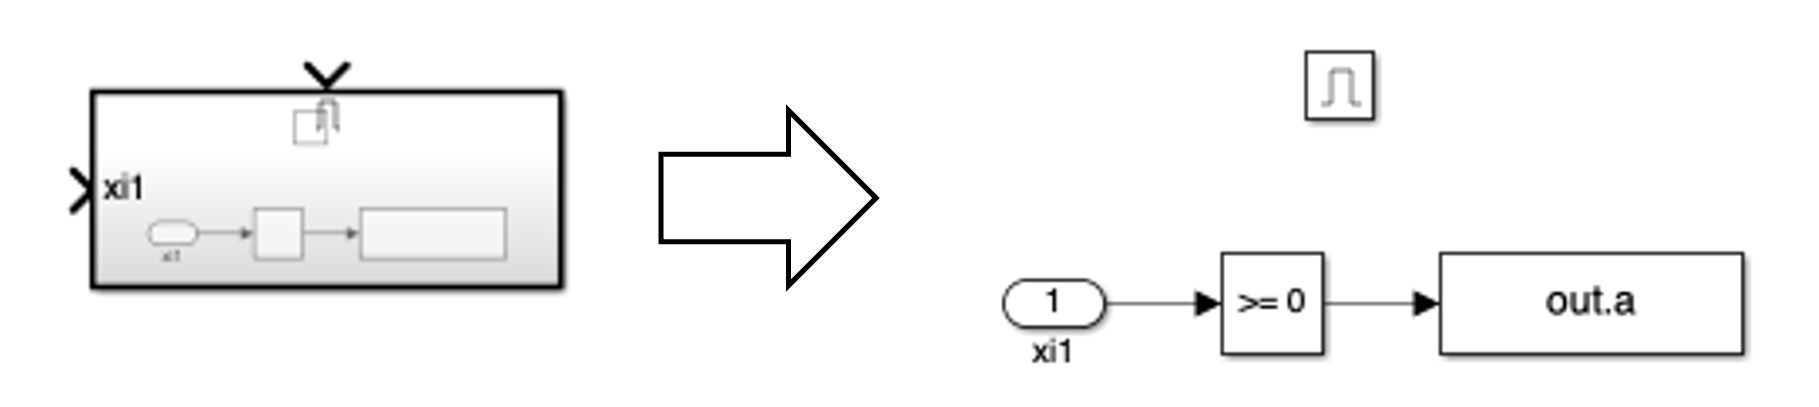
The decision subsystem is also enabled.
This is because decisions should be made on every other interpolator output on average.
The enable signal indicates which interpolator outputs represent the desired signal space projections.
An example of the enabled decision subsystem for binary PAM is shown below
Exercise
- Incorporate the symbol timing synchronization PLL into a binary PAM detector.
- For the detector input, use the From File block and set the Filename to bbtrdata.mat and the sample time to 1.
-
Set the simulation parameters as follows:
Simulation Time Start time: 0.0 Stop time: (12+1000+3360+16)*8 Solver selection Type: Fixed-step Solver: discrete (no continuous states)
Note the additional "16" in the run time is to give the timing PLL time to lock. - Run the simulation.
- The detector produces approximately 4390 decisions. (The exact number depends on the number of times the strobe is high. This, in turn, depends on the dynamics of your symbol timing PLL.)
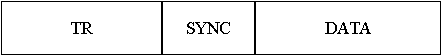
- To find the data, look for the 16-bit SYNC pattern in the detector output. Once you find it, the following 3360 bit decisions correspond to 480 7-bit ASCII characters. Determine the message using either your Matlab script or an ASCII Table.
- Plot the fractional interpolation interval (mu) and use this plot to estimate how long (measured in bits) it took for your timing PLL to lock.
Brigham Young University - Provo |
Fulton College of Engineering |
The Church of Jesus Christ of Latter-day Saints
Department of Electrical and Computer Engineering, BYU, Provo, UT 84602 - (801)422-4012 - Copyright 2009. All Rights Reserved
Department of Electrical and Computer Engineering, BYU, Provo, UT 84602 - (801)422-4012 - Copyright 2009. All Rights Reserved